Ares — Led by Braxton Herold
Control Algorithm
Despite how nerdy they are, control algorithms are one of the most important parts of any TVC rocket.
Ares — Led by Braxton Herold
Despite how nerdy they are, control algorithms are one of the most important parts of any TVC rocket.
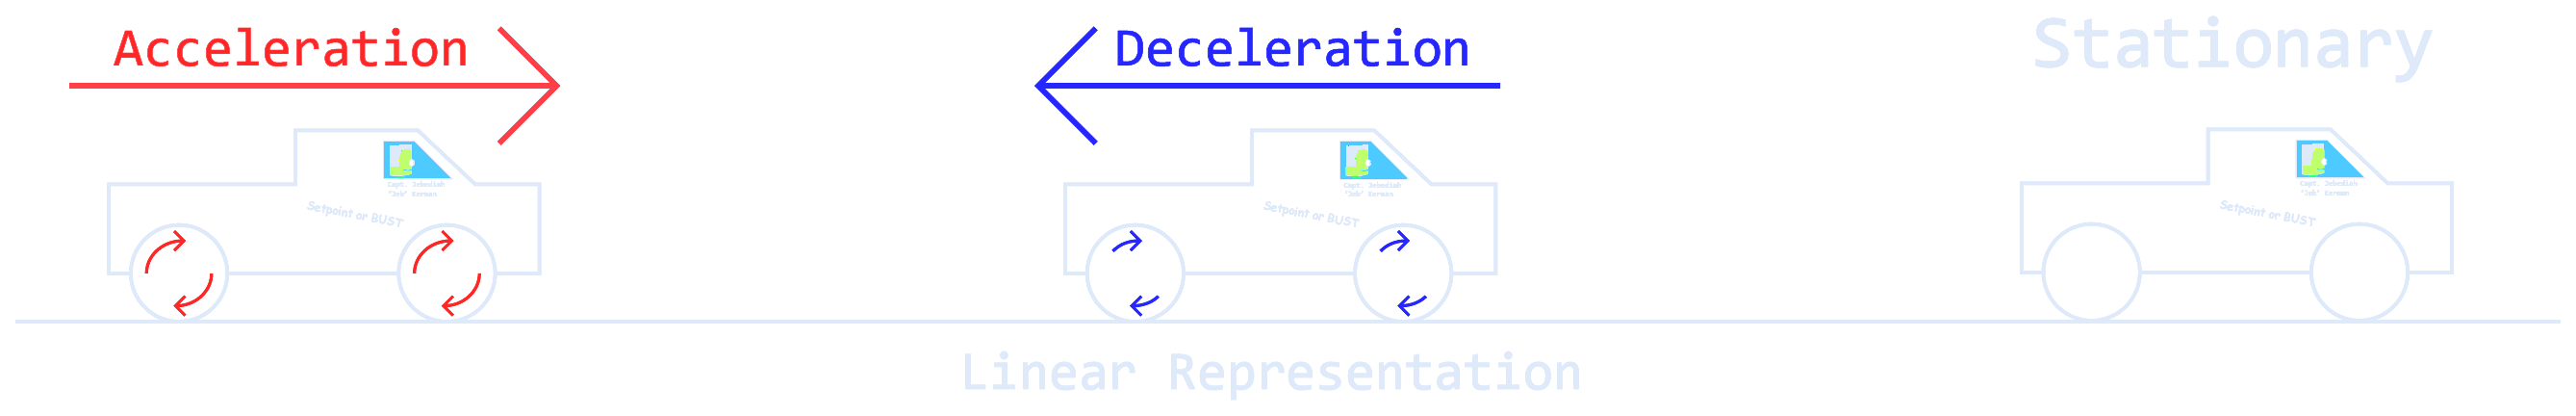
Picture a car 20 meters from the only shady spot in a parking lot. Floor it the whole way and you only start slowing down after you've passed it. Acceleration builds up into speed, and speed into distance, so reaching a target means knowing when to ease off. Active control is the logic that decides when to push and when to brake, based on where you are right now.
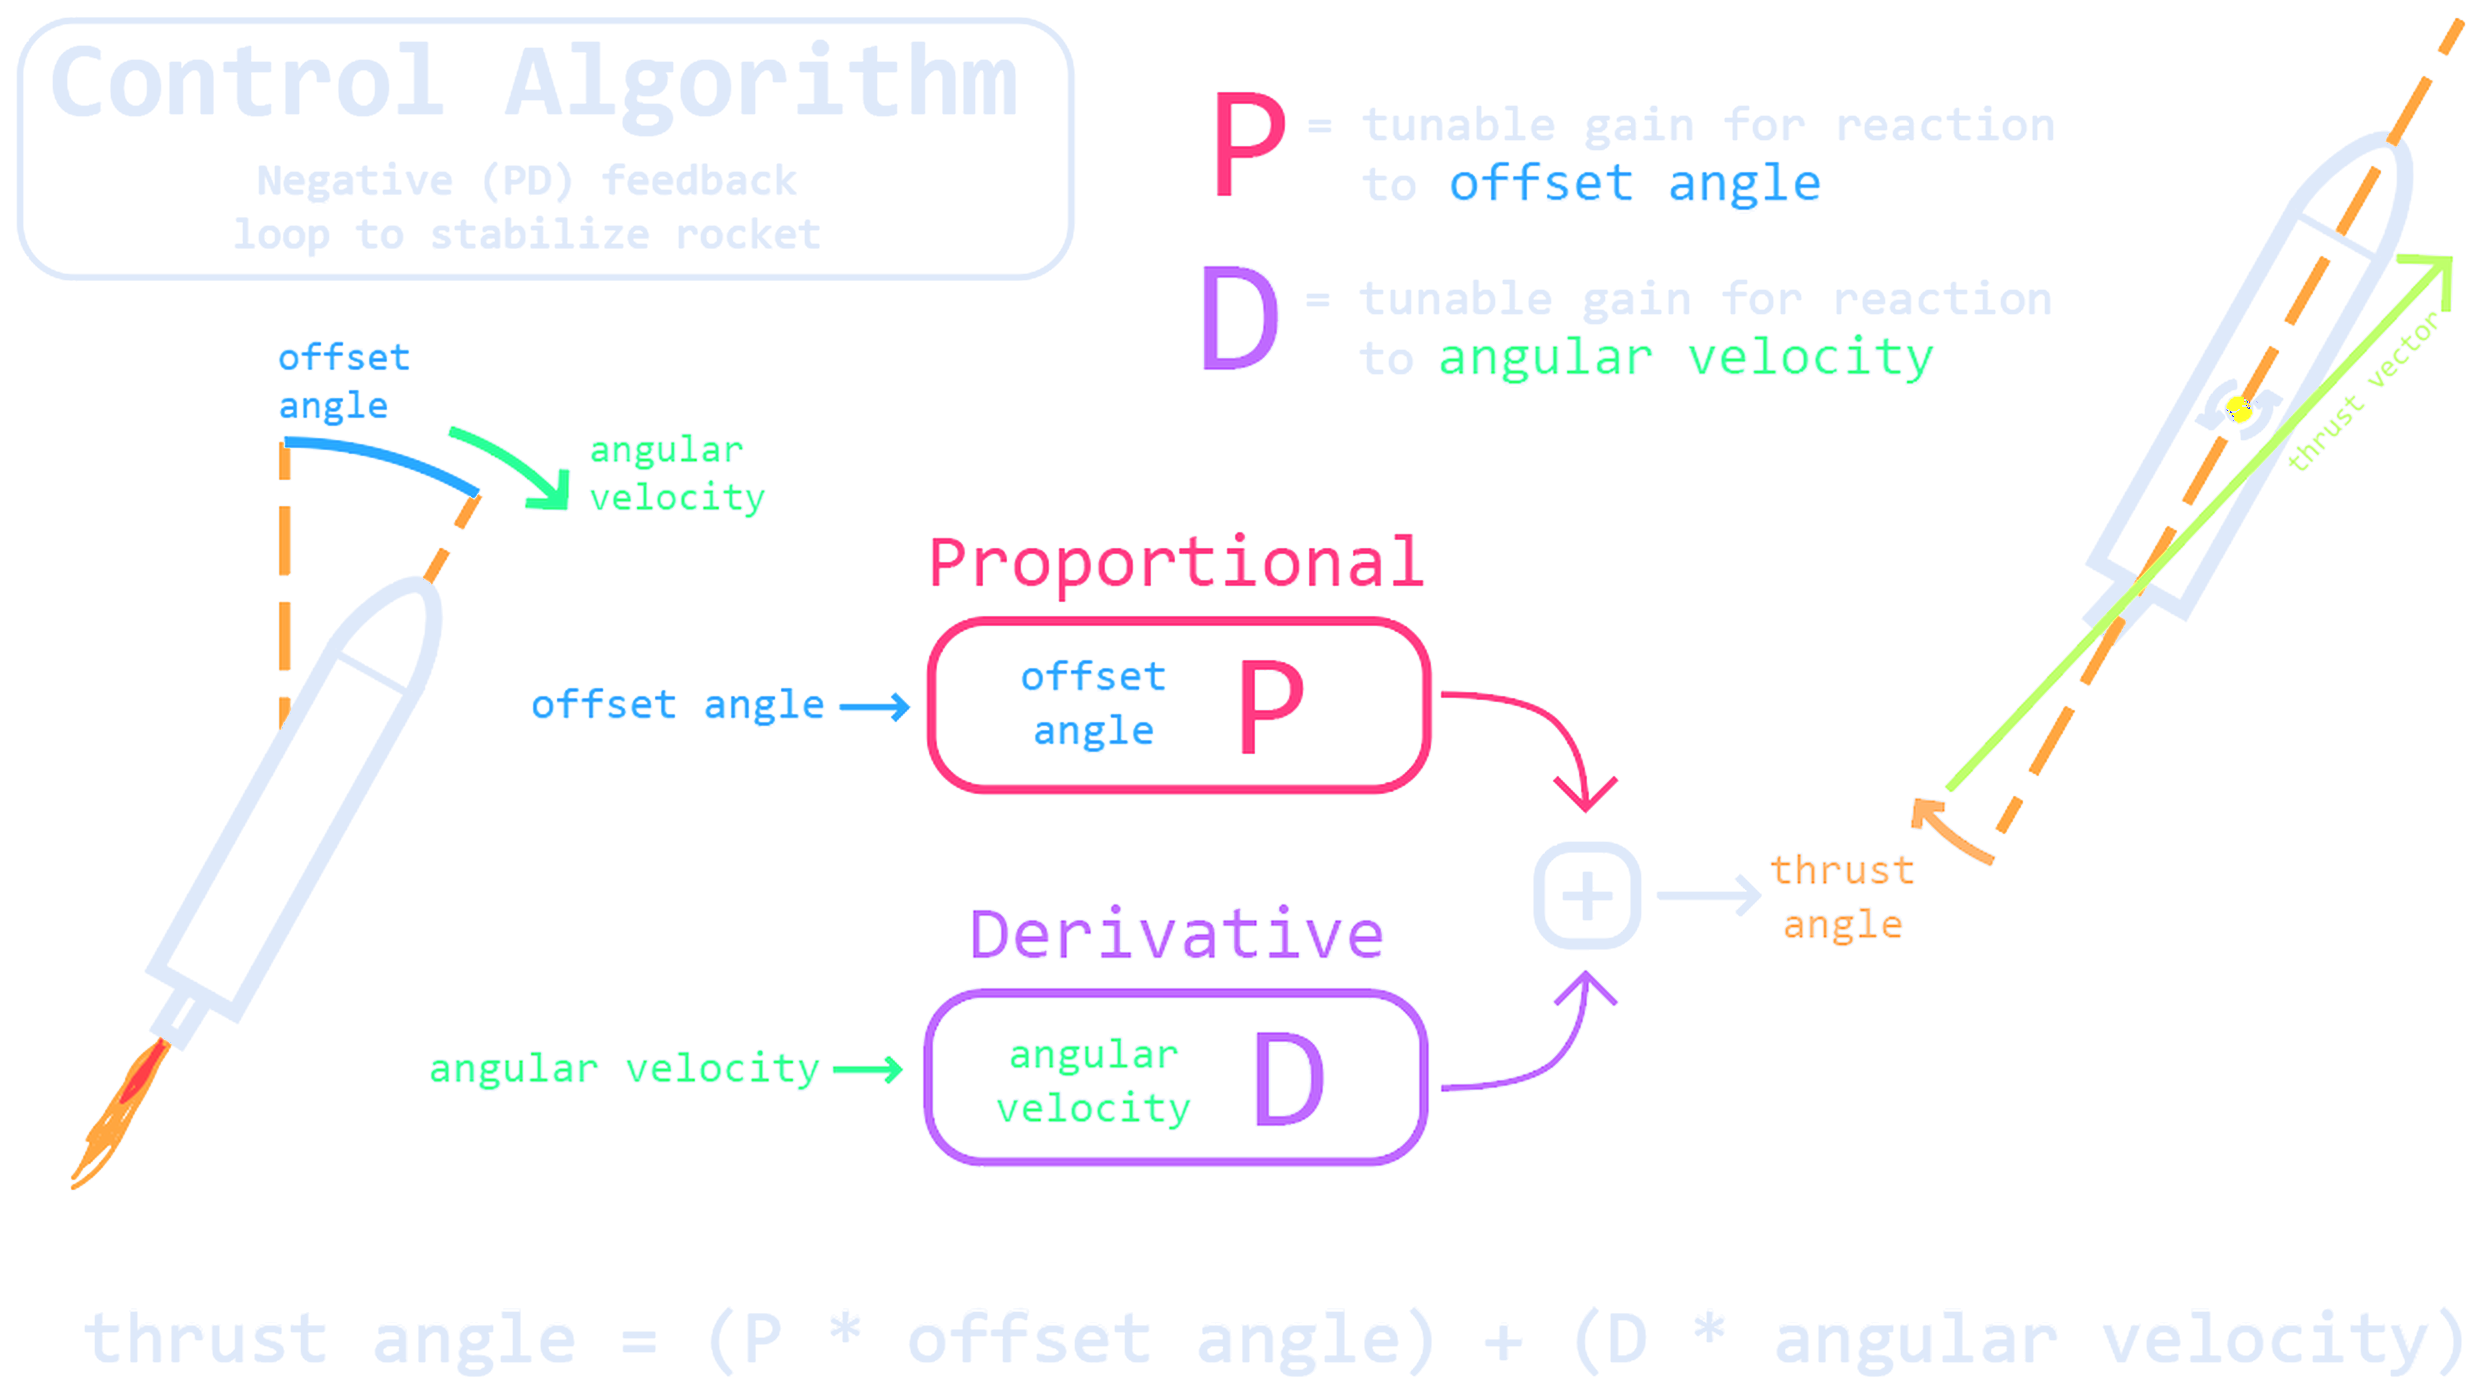
Ares runs proportional-derivative (PD) control, a simpler form of the common PID algorithm. The proportional term pushes the motor back toward vertical in proportion to how far the rocket has tilted. The derivative term reacts to how fast it is tilting, so the correction eases off before it overshoots. We simulated the loop in MATLAB Simulink to tune both gains before flying.